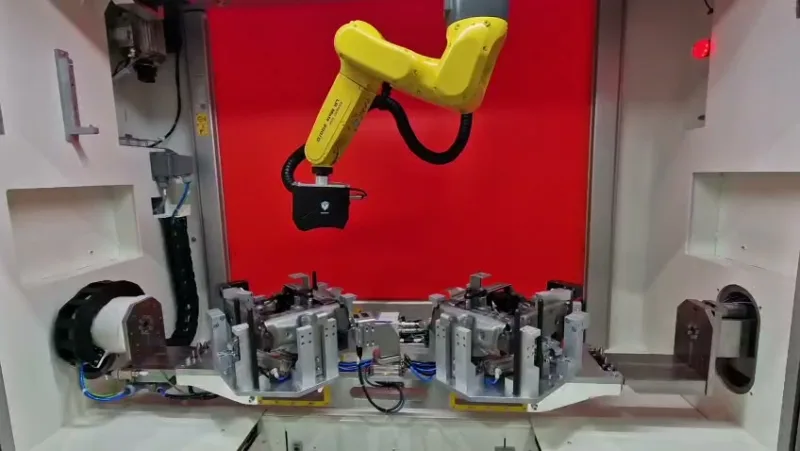
To inspect a large part, the sensor must see the measurement points from the right angle. ScanMach combines bumper positioning with a robot carrying a 3D sensor.
The operator loads the bumper in the fixture. The positioner turns it for measurement. A FANUC LR Mate 200iD moves along a linear rail and guides a GOCATOR 3210 sensor above the areas to be measured.
The short clip shows part of a measurement cycle. The longer edit shows the station in several positions. The case study includes photos of the robot, sensor and fixture.
Related project · Short measurement clip · Workstation compilation · Contact us · Blog

 Česky
 Deutsch
 Italiano
 Polski
 Français
 Srpski